Overview
What you'll build
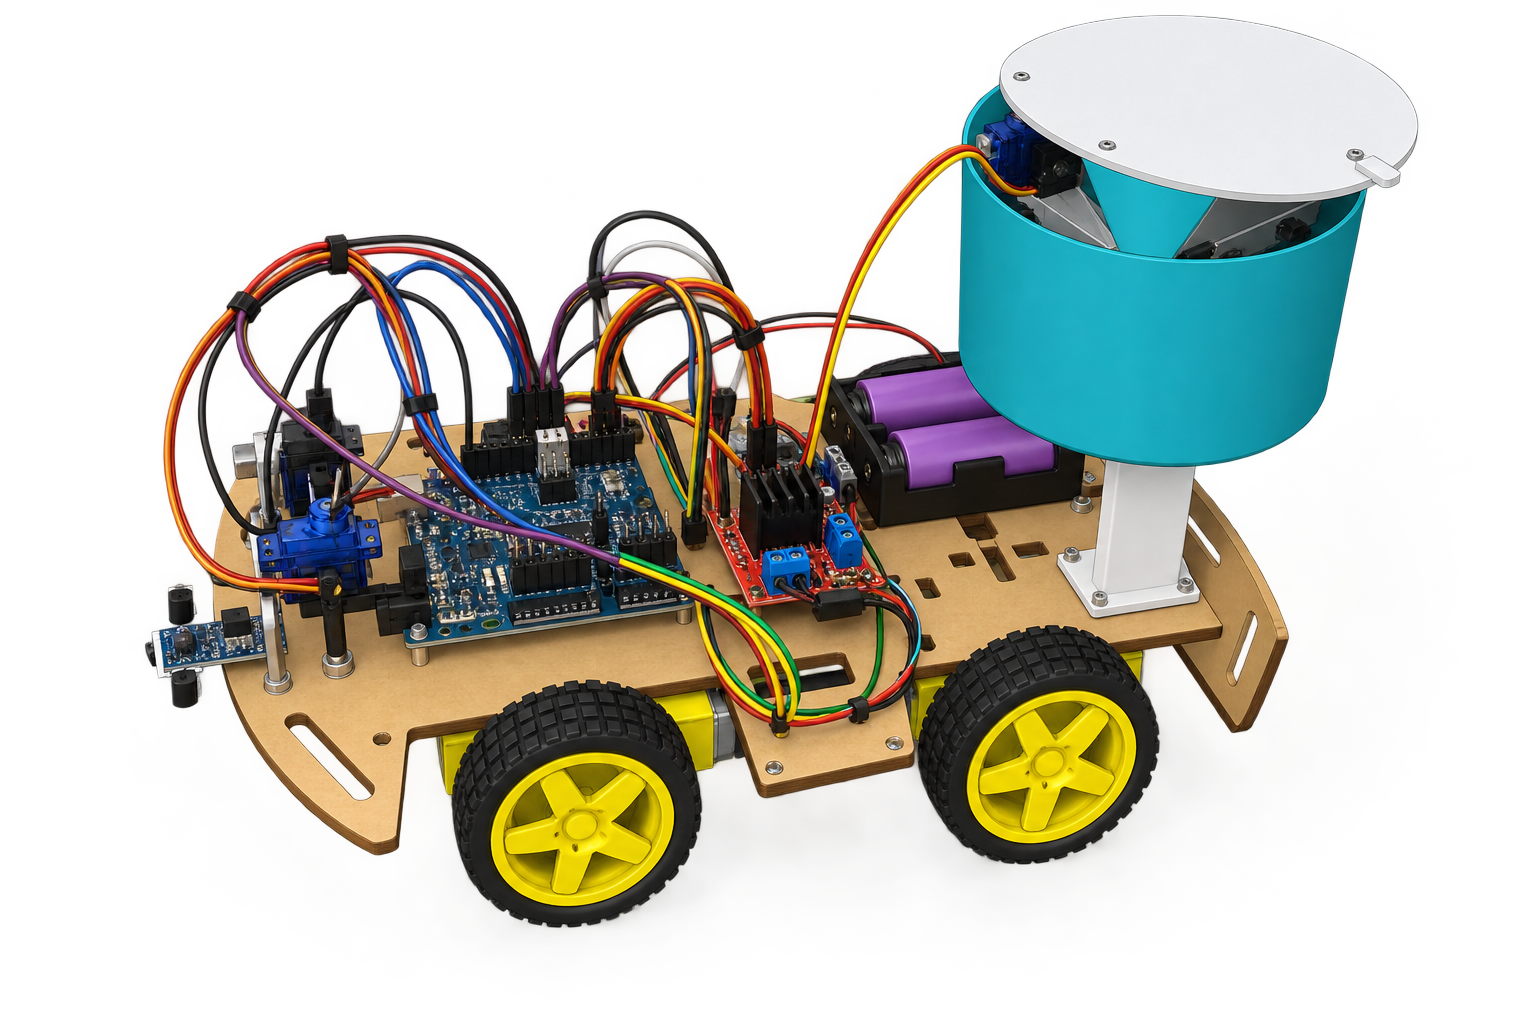
A two-wheeled robot that follows a black line on a white surface, using IR reflectance sensors and a tuned PID controller for smooth, fast cornering.
How it works
Two IR sensors detect the line edges; the Arduino computes a correction with a lightweight PID loop and drives the motors through an L298N driver. We include a calibration routine so it works on any track.
You'll learn
- Reading and calibrating IR sensor arrays
- Writing a simple, readable PID controller
- Motor driver wiring and PWM speed control
- Tuning for speed vs. stability
Components & parts list
Everything you need to build this. Links help support the channel at no extra cost to you.
Some links are affiliate links. Prices shown are indicative — check the store for current pricing.